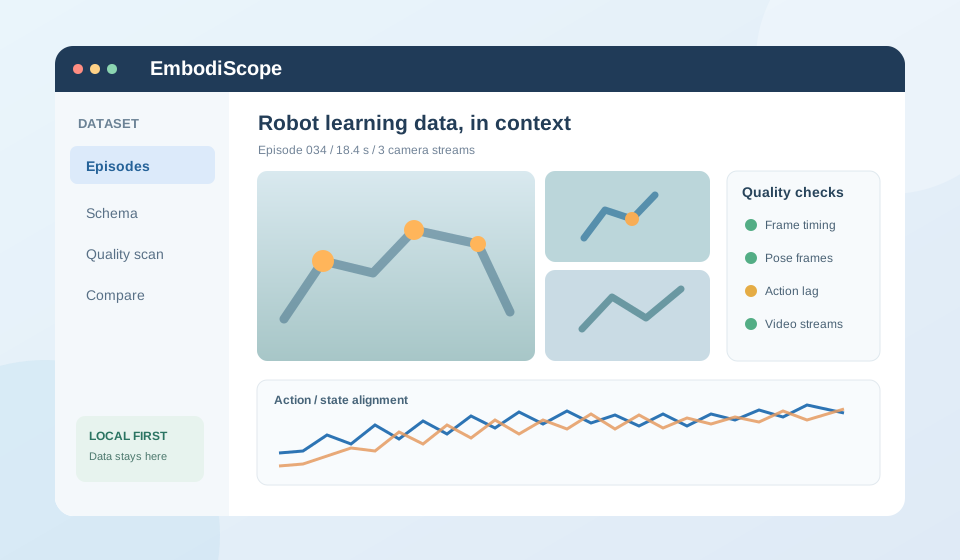
EmbodiScope
A browser-based workspace for inspecting and quality-checking robot-learning data. It helps reveal mismatched action semantics, coordinate frames, timing, and video streams before they become training failures.
Zhirui GaoResearcher, Embodied AI @ Huawei
Email: [Curriculum Vitae] [Google Scholar] [GitHub] [WeChat]
🏆 5× CCF-A Papers
🏅 1× SIGGRAPH Asia 2026
🥇 1× ECCV 2026 Oral
🤖 Embodied AI
🧊 3D Vision
🌍 World Models
|

|
Hi there👋, my name is Zhirui Gao (in Chinese: 高志锐).
I received my Ph.D. degree from National University of Defense Technology (2021–2026), supervised by Prof. Kai Xu, Prof. Wei Chen, and Assoc. Prof. Renjiao Yi. Prior to that, I earned my Bachelor's degree from China University of Geosciences (2017–2021).
I am currently a researcher at Huawei focusing on Embodied AI. My research interests broadly lie in 3D Vision and Embodied Intelligence, including 3D Reconstruction, World Models, WAM, and VLA models.
I am open to collaborations and actively recruiting research interns and full-time employees. Feel free to reach out via email!
I work on the data and research workflows behind embodied intelligence, with a focus on trustworthy robot-learning datasets and keeping up with VLA and world action model research.
A browser-based workspace for inspecting and quality-checking robot-learning data. It helps reveal mismatched action semantics, coordinate frames, timing, and video streams before they become training failures.
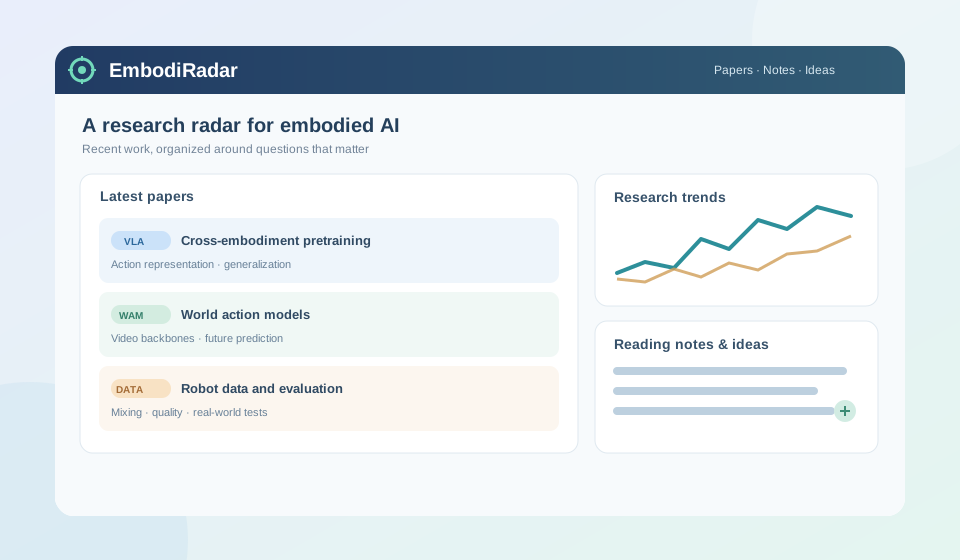
My research radar for recent embodied-AI papers and industry updates. It brings together weekly trends, reading notes, topic collections, and ideas so I can connect new results with my own research questions.
Questions I am tracking
🏆 SIGGRAPH Asia 2026
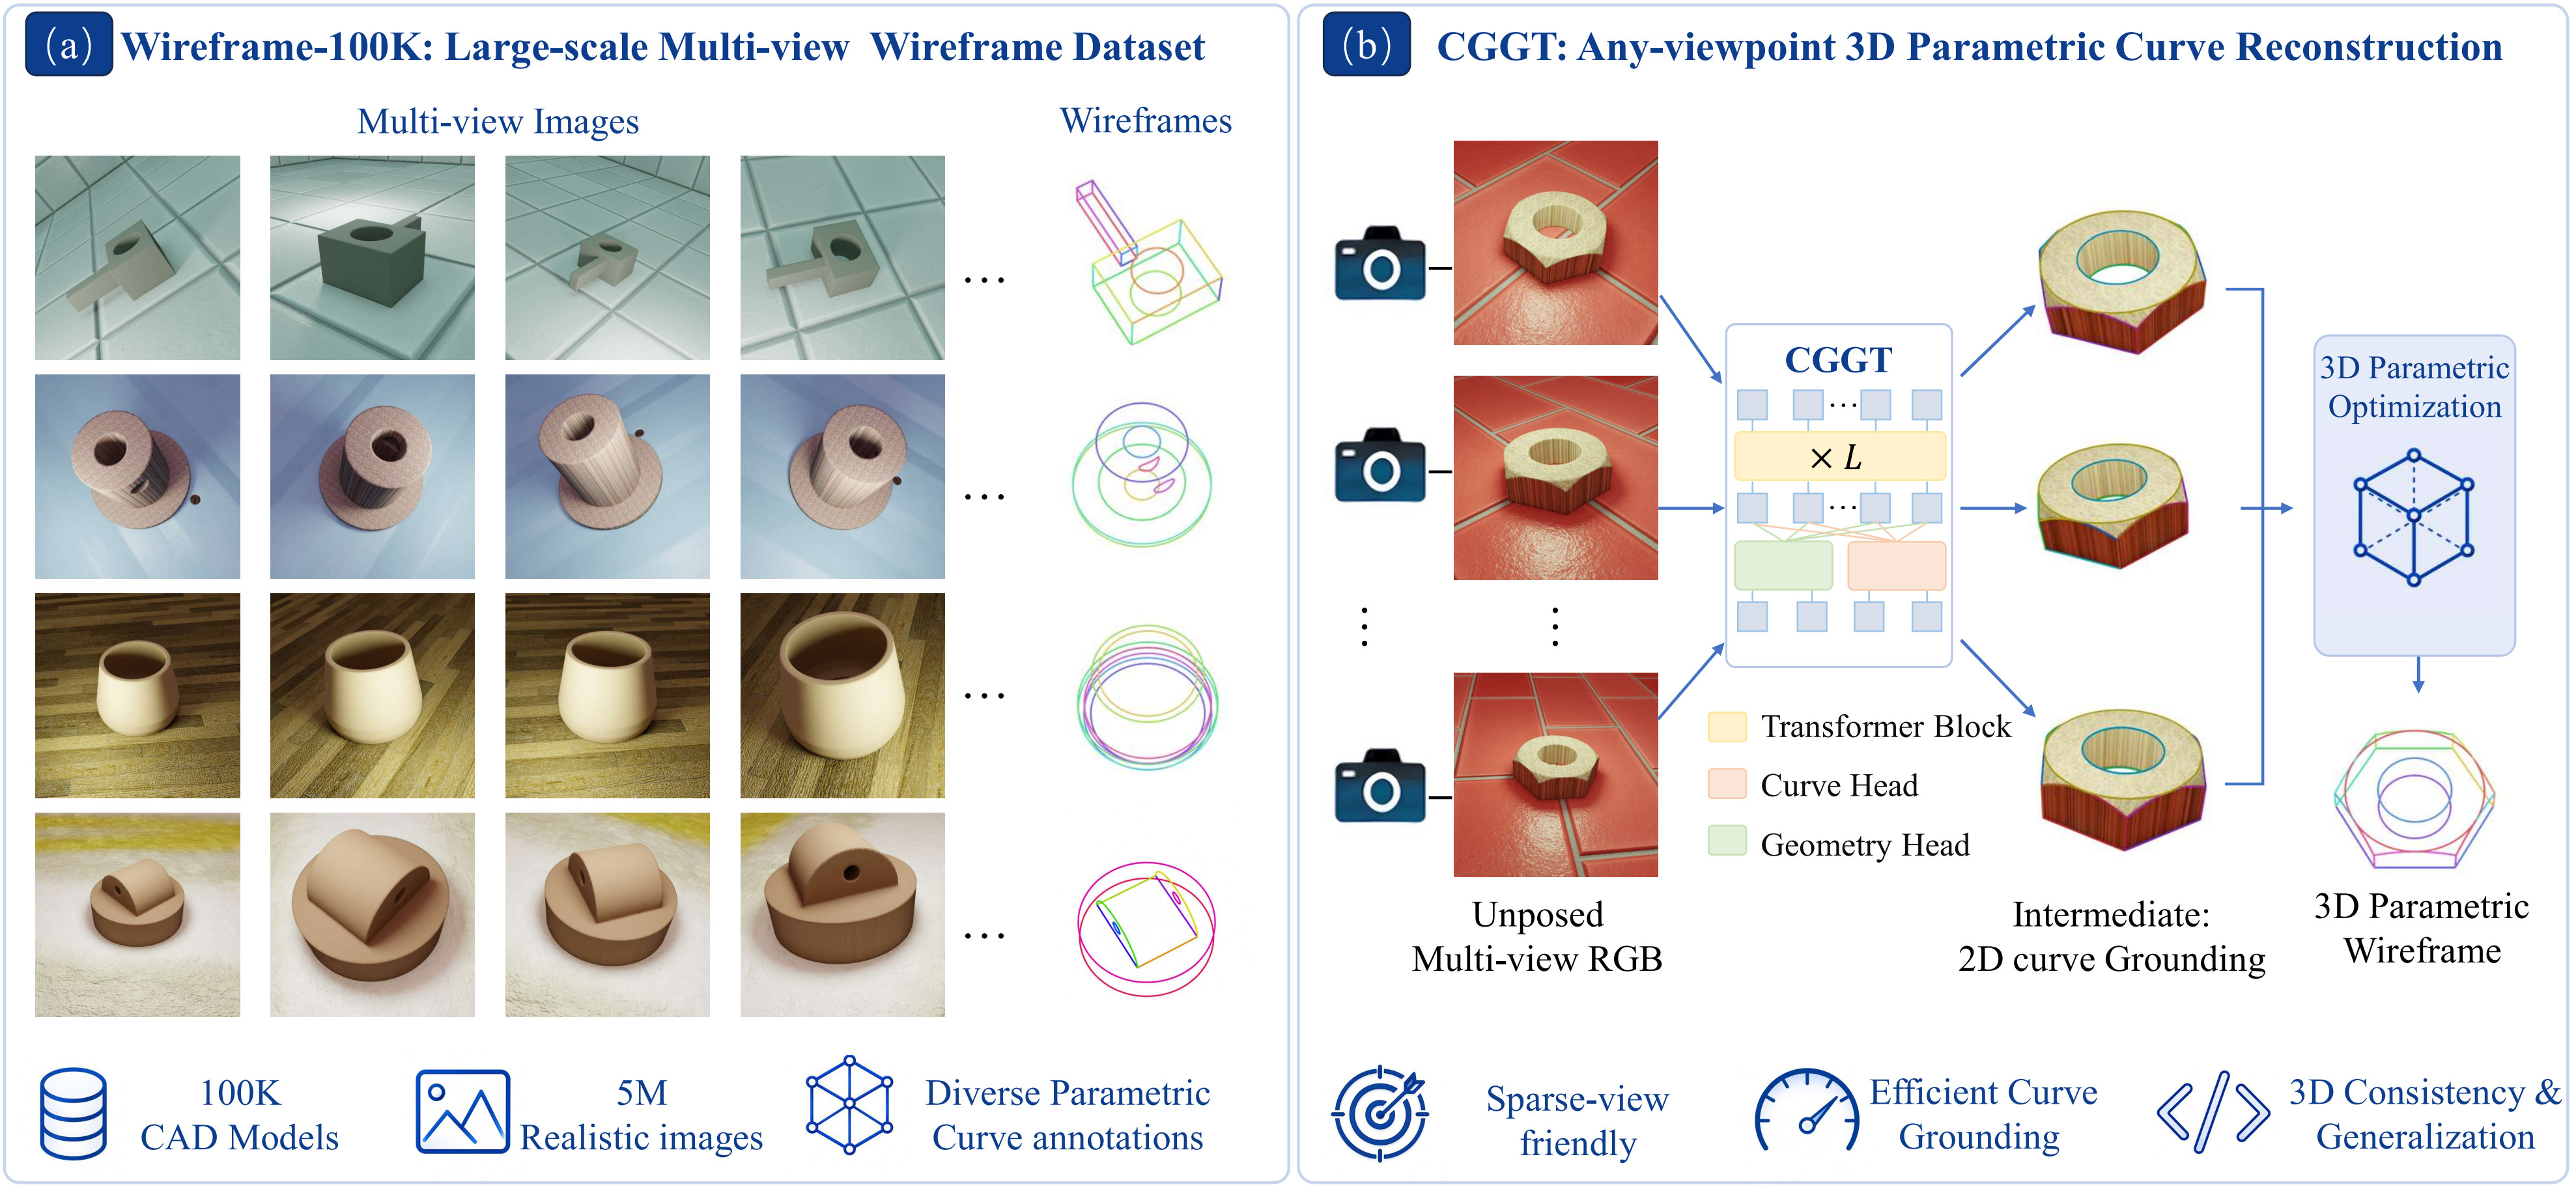
|
|
🏆 ECCV 2026 Oral

|
|
PG 2025 CCF-B

|
|
🏆 ICCV 2025 · CCF-A

|
|
🏆 ICCV 2025 · CCF-A

|
|
IEEE TCSVT 2025 CCF-B

|
|
🏆 ICCV 2023 · CCF-A

|
|
CVMJ 2023 · CCF-B(IF:18.3)

|
|
🏆 TIP 2023 · CCF-A

|
|
🏆 CVPR 2023 · CCF-A

|
|